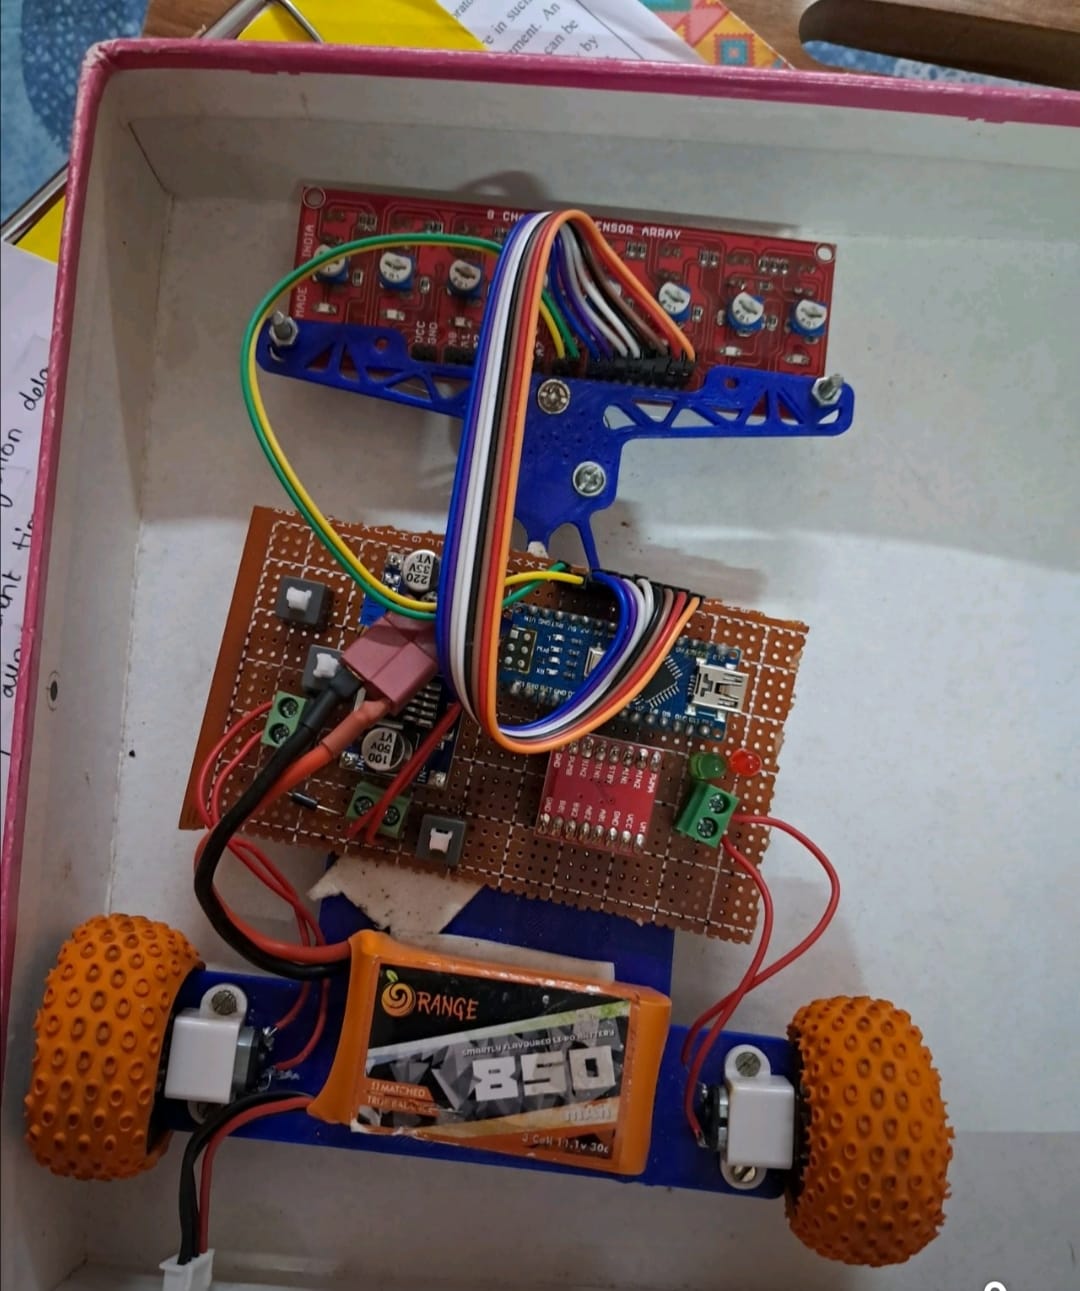
This project was an autonomous line-following robot designed and built using an Arduino Nano microcontroller. The robot uses an 8-array IR sensor to detect and follow black paths on white surfaces or vice versa, adjusting motor speeds dynamically for turns and intersections.
This particular work was when I was a member of T-Rex Robotix, a robotics team playing in and around kolkata and beyond.
I integrated the TB66 motor driver for stable motor control, with a buck converter for efficient power regulation. The chassis design focused on weight balance and efficient torque distribution, enabling smooth and stable movement. It was totally designed and 3d printed.
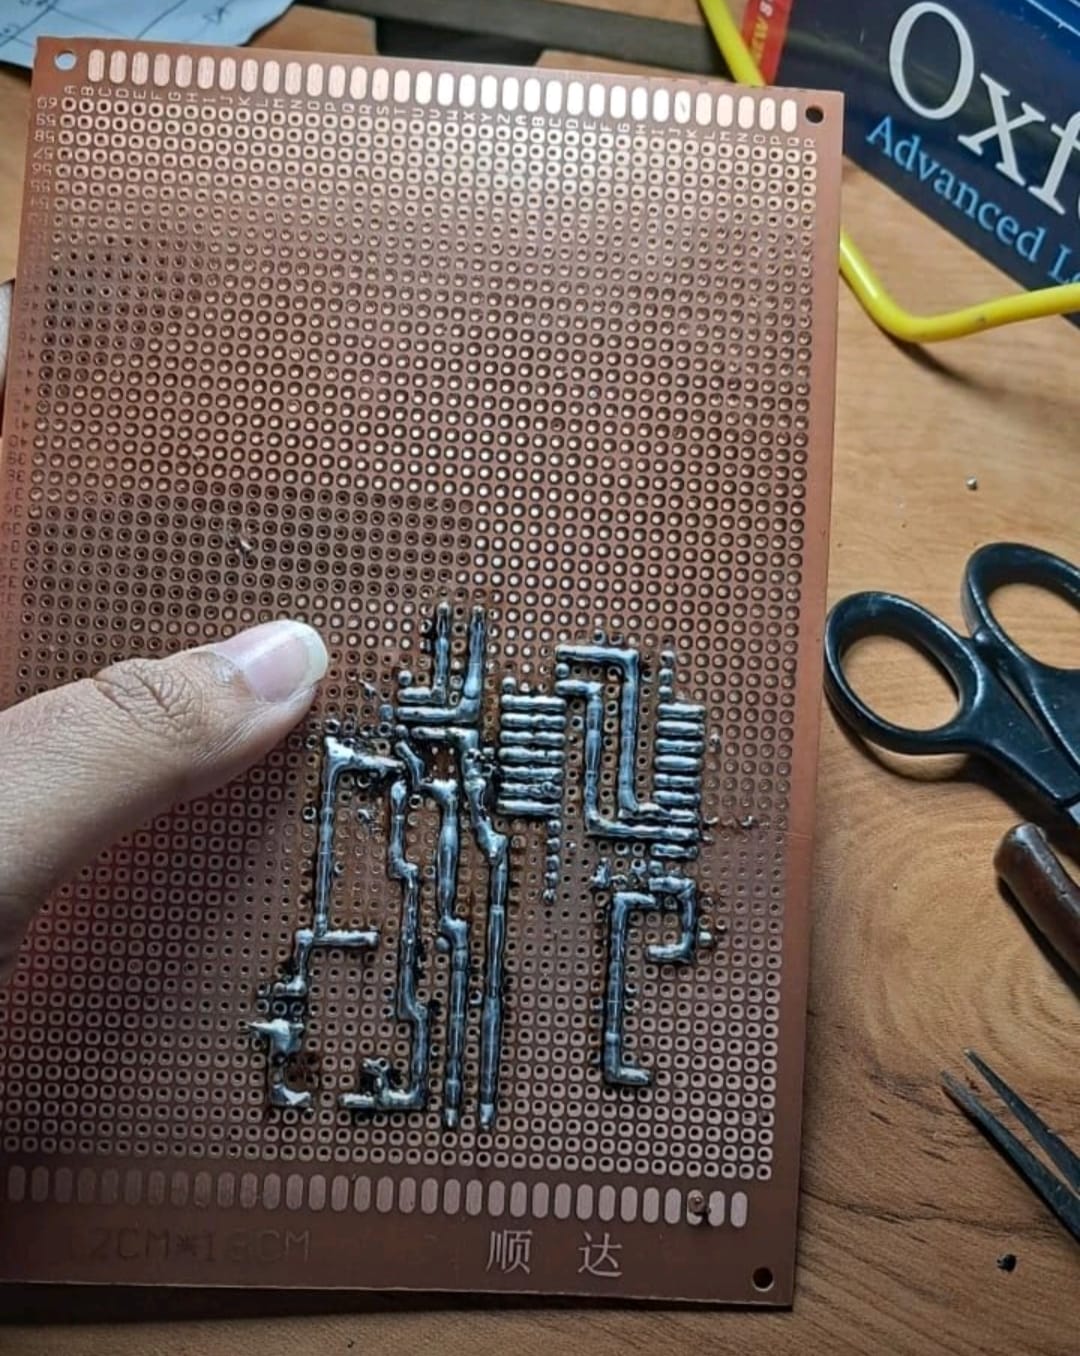
All connections were custom-soldered . This project helped me strengthen my understanding of embedded systems, control logic, and real-world circuit implementation.